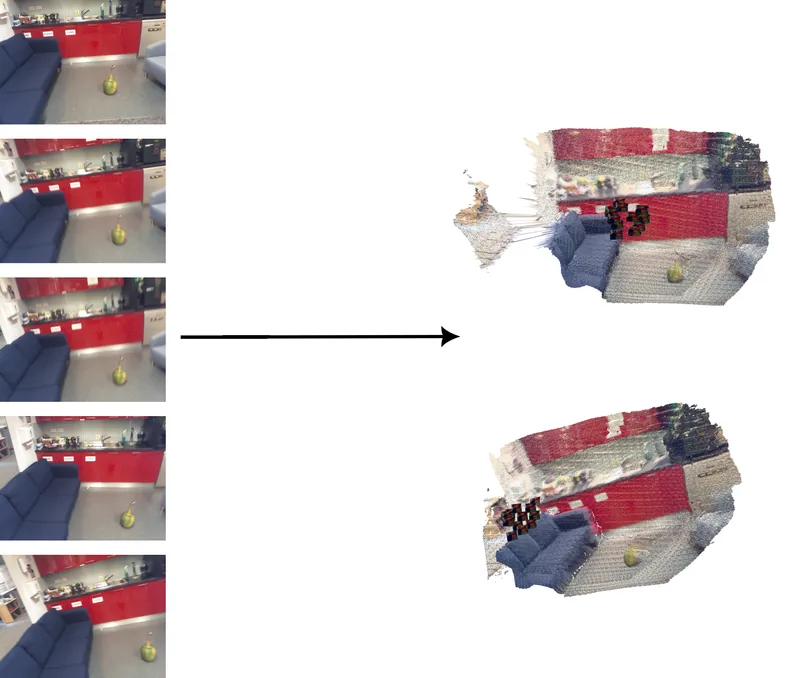
RayPose-MVS
A feed-forward model that predicts dense 3D geometry and camera pose in a single pass, without bundle adjustment or RGB inputs, trained on ~1% of the data other methods use.
Projects
Projects in computer vision, 3D reconstruction and graphics. Most of them are implemented from the maths up instead of built on library calls.
A feed-forward model that predicts dense 3D geometry and camera pose in a single pass, without bundle adjustment or RGB inputs, trained on ~1% of the data other methods use.
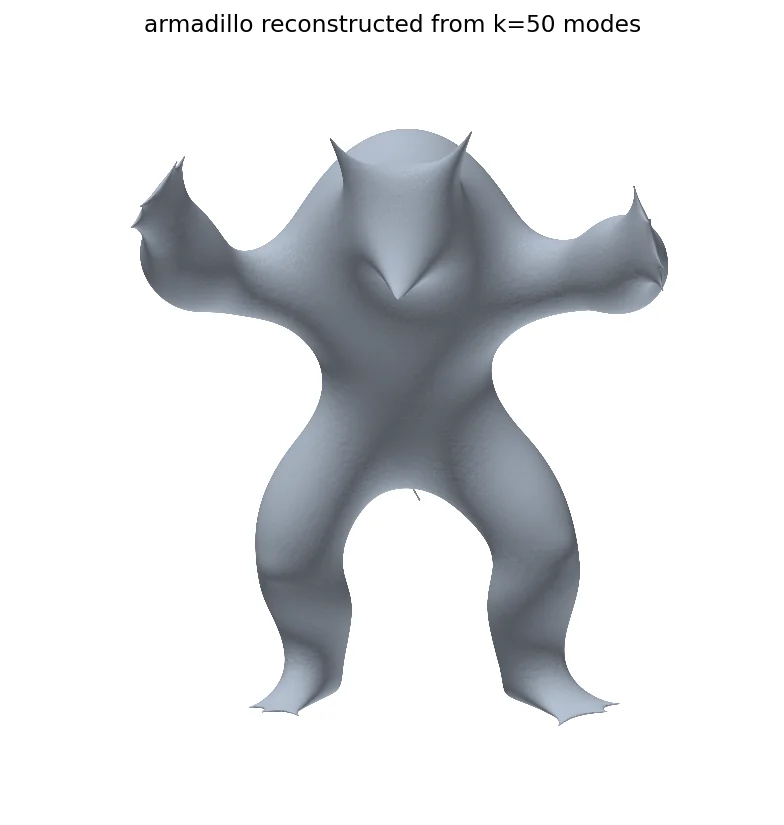
Registration, halfedge structures, discrete curvature, the spectrum of the Laplace–Beltrami operator, and denoising by curvature flow, with every operator and solver implemented in NumPy and SciPy.
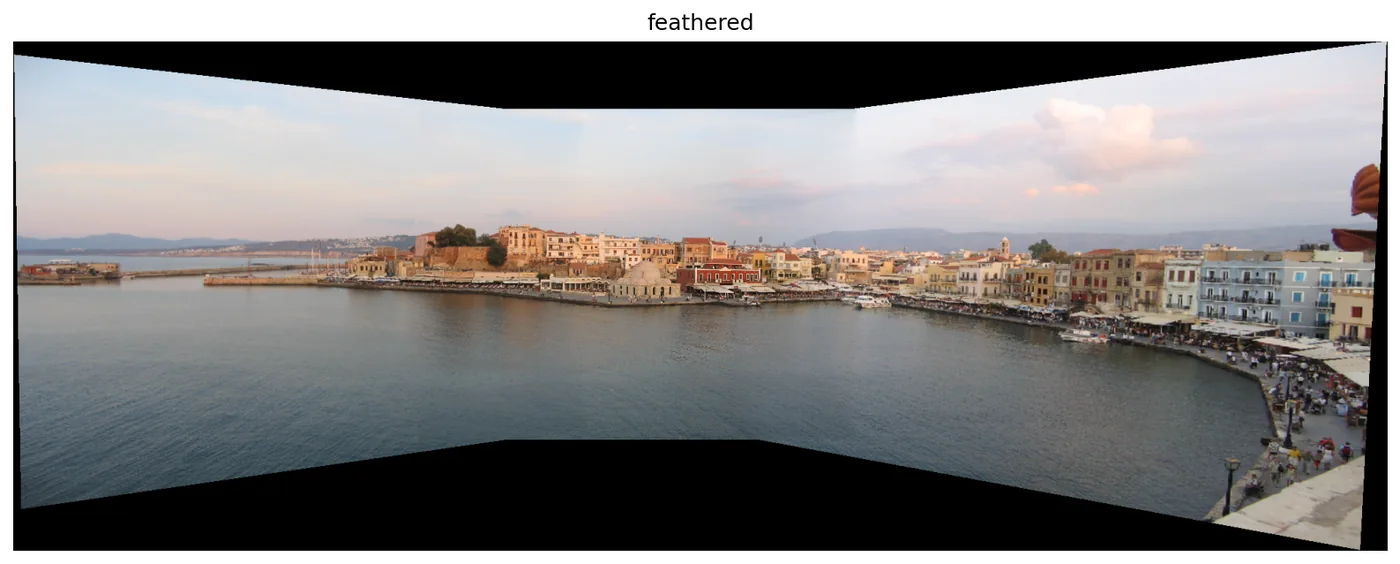
Homography estimation, RANSAC, corner detection, panorama stitching, metric rectification, plane pose, template tracking and Zhang's calibration, implemented without any OpenCV geometry calls.
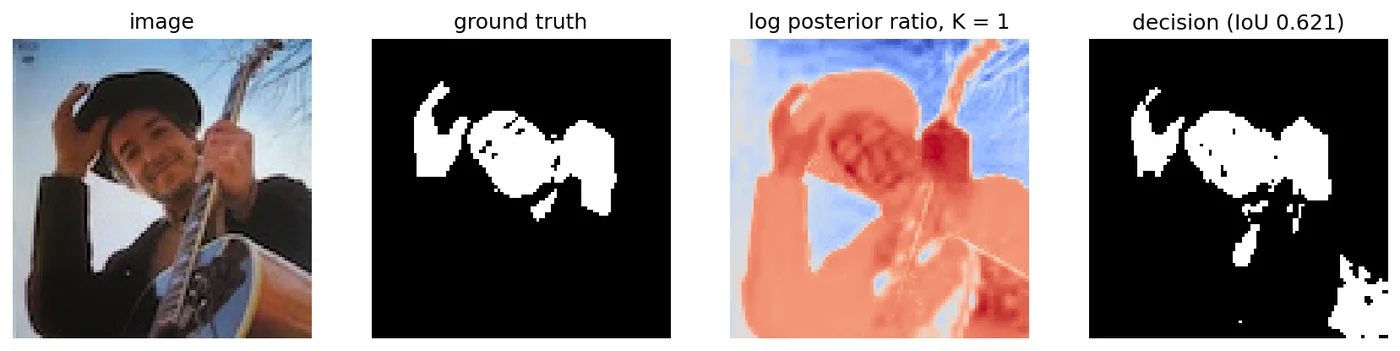
Density models, mixtures fitted with EM, generative classification and particle filtering from scratch, where the mixture fitted in the first half is used as the appearance model for the tracker in the second.
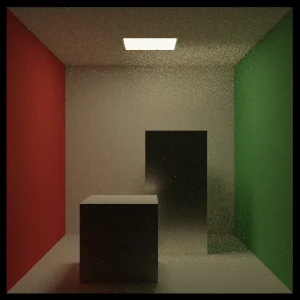
A path tracer in C++ with no dependencies, along with 24 statistical checks to verify that its estimator is correct, since a rendered image alone cannot show this.
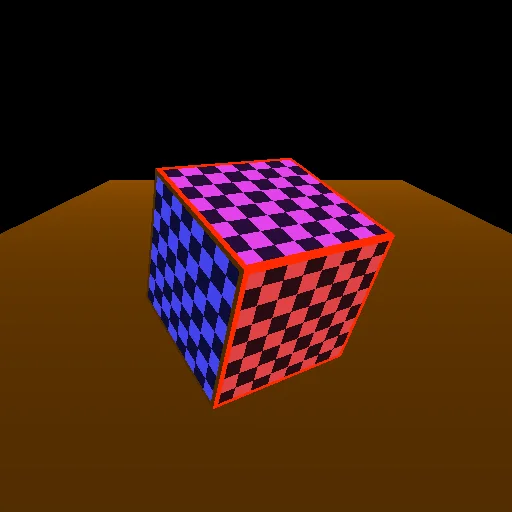
The rasterisation pipeline reimplemented inside a fragment shader and compared against the hardware pixel by pixel, which showed that hardware does not rasterise in floating point.
Seamless cloning, mixed gradients, texture flattening and interpolation fill, where each technique is the same sparse linear solve with a different guidance field.
Two ways to morph one face into another, implemented from scratch in NumPy, using either a Delaunay mesh of per-triangle affine warps or a meshless warp driven by distance-weighted landmark displacements.